Simultaneous Task Allocation and Planning for Multi-Robots under Hierarchical Temporal Logic Specifications
Follow six robots as their actions complete a mission, one subtask at a time.
An office, shared
by six robots.
Desks, meeting rooms, service rooms, and public corridors give the logical propositions a physical location.
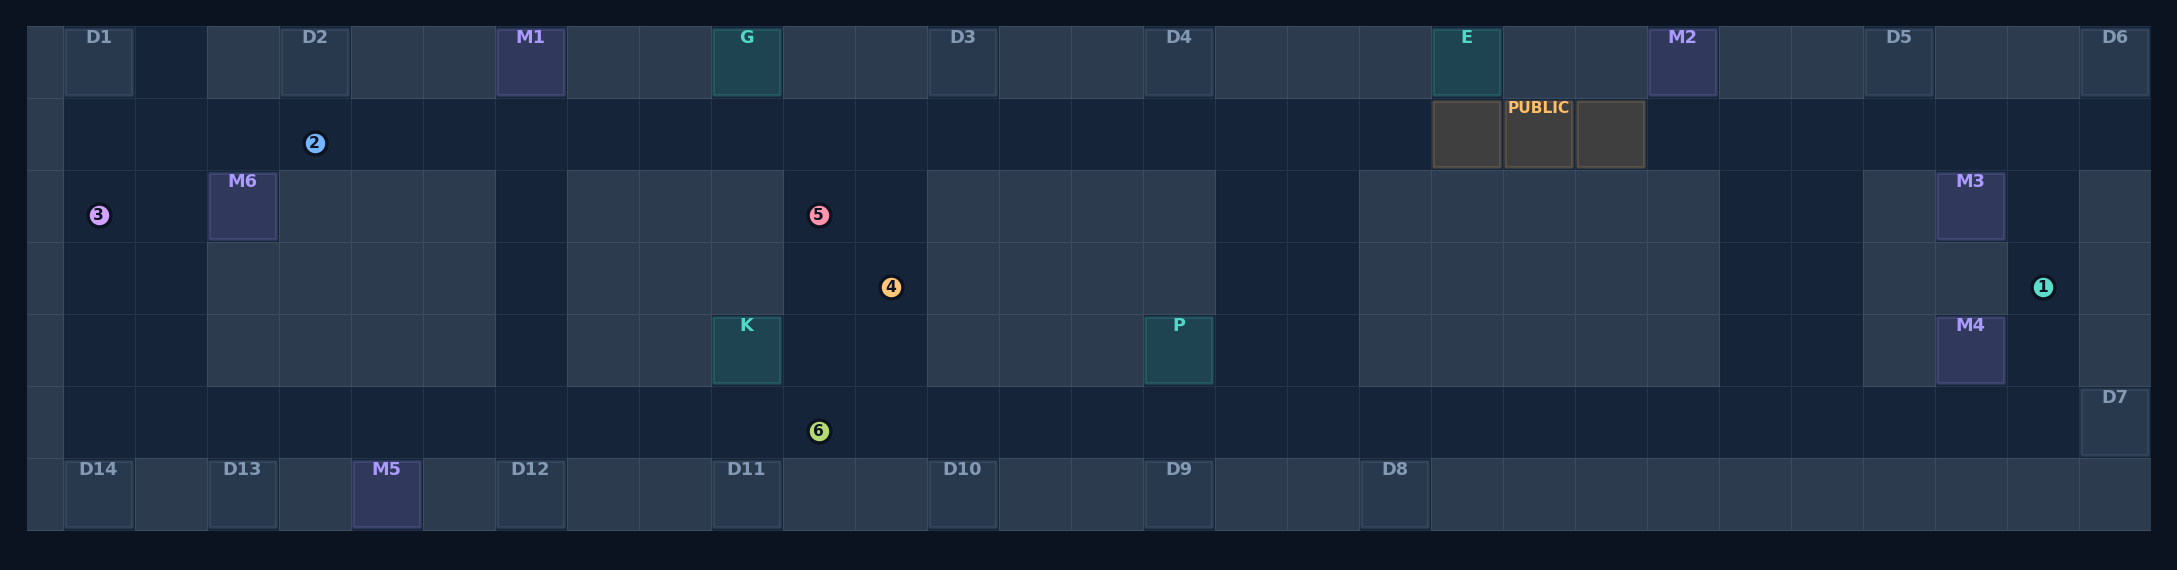
Initial positions with seed 42. The same map and robot colors appear in the videos.
Watch the plan unfold.
Select a scenario, then press play. Use fullscreen for the LTL details.
Paper-bin collection and return
Move the full paper bin from D5 to garbage room G, dispose of its contents, and return an empty bin to D5.
Task requirements
- Keep the full bin out of public areas.
- Both transport tasks must finish.
Read the task
as it happens.
The progress display connects logical requirements to robot actions and positions in the recorded plan.
The root p0 groups mission branches. Leaf cards track concrete robot tasks; in Scenario 4, p301 adds an intermediate photo mission.
The robot indicators show current actions. Public-cell hatching applies to robots carrying a bin or document; camera states reflect meeting-room actions.
Amber indicates active work, green indicates completion, and a dim outline means pending. Child completion events contribute to parent progress.
The demos preserve the planner’s execution with --cost=minmax. No collision avoidance or parking schedule is added. Collision reports are diagnostics and do not alter robot paths.
AI2THOR simulation.
The original repository recording, retained with its frames and audio. This is a separate demonstration, not a rerun of the four scenarios above.
Open original demonstration ↗Built on formal
task specifications.
Xusheng Luo and Changliu Liu. “Simultaneous Task Allocation and Planning for Multi-Robots under Hierarchical Temporal Logic Specifications.” IEEE Transactions on Robotics, 2025.
Cite this work · BibTeX
@article{luo2025simultaneous,
  title={Simultaneous Task Allocation and Planning for Multi-Robots under Hierarchical Temporal Logic Specifications},
  author={Luo, Xusheng and Liu, Changliu},
  journal={IEEE Transaction on Robotics},
  year={2025},
  publisher={IEEE}
}